Rhandy Cardenas

Industrial PhD Researcher · AI & Autonomous Driving

Planning safer autonomous driving.

Groupe Renault × Université de Technologie de Compiègne
Heudiasyc UTC Laboratory

PhD defense scheduled for December 2026

Explore my projects

Experience

Industrial experience

Research, engineering and development in industry.

Industrial PhD Research Engineer – ADAS/AD

Renault Group / Heudiasyc UTC

Jul 2023 – Jul 2026
  • Analyzed tactical decision-making approaches to guide the behavior planning architecture.
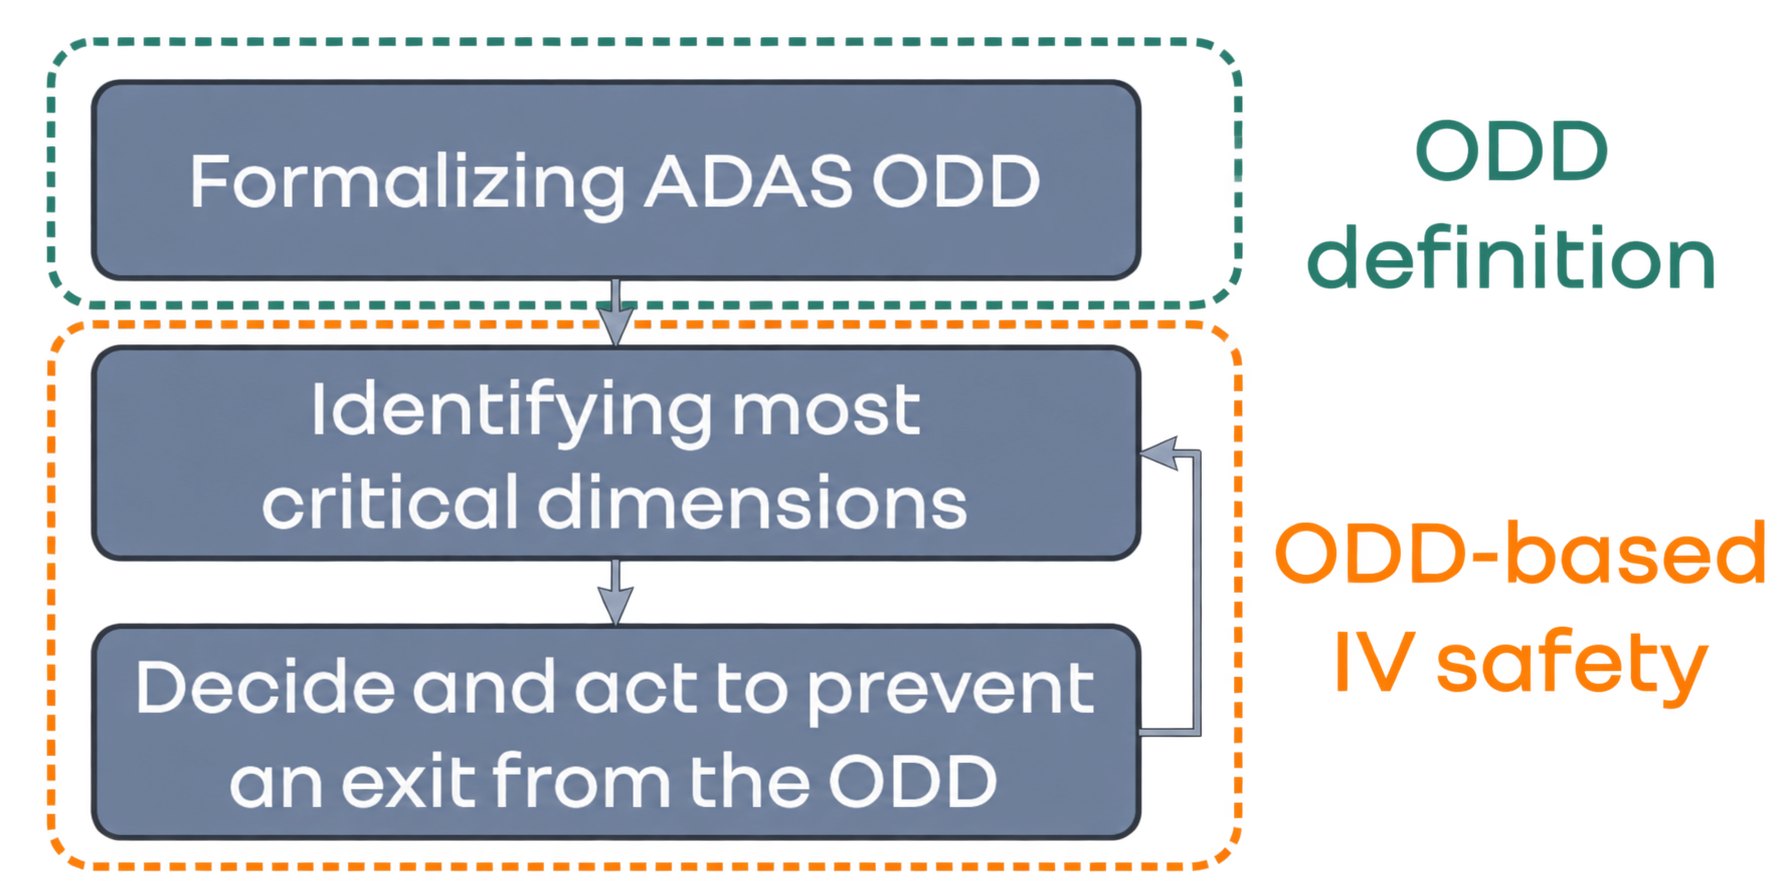
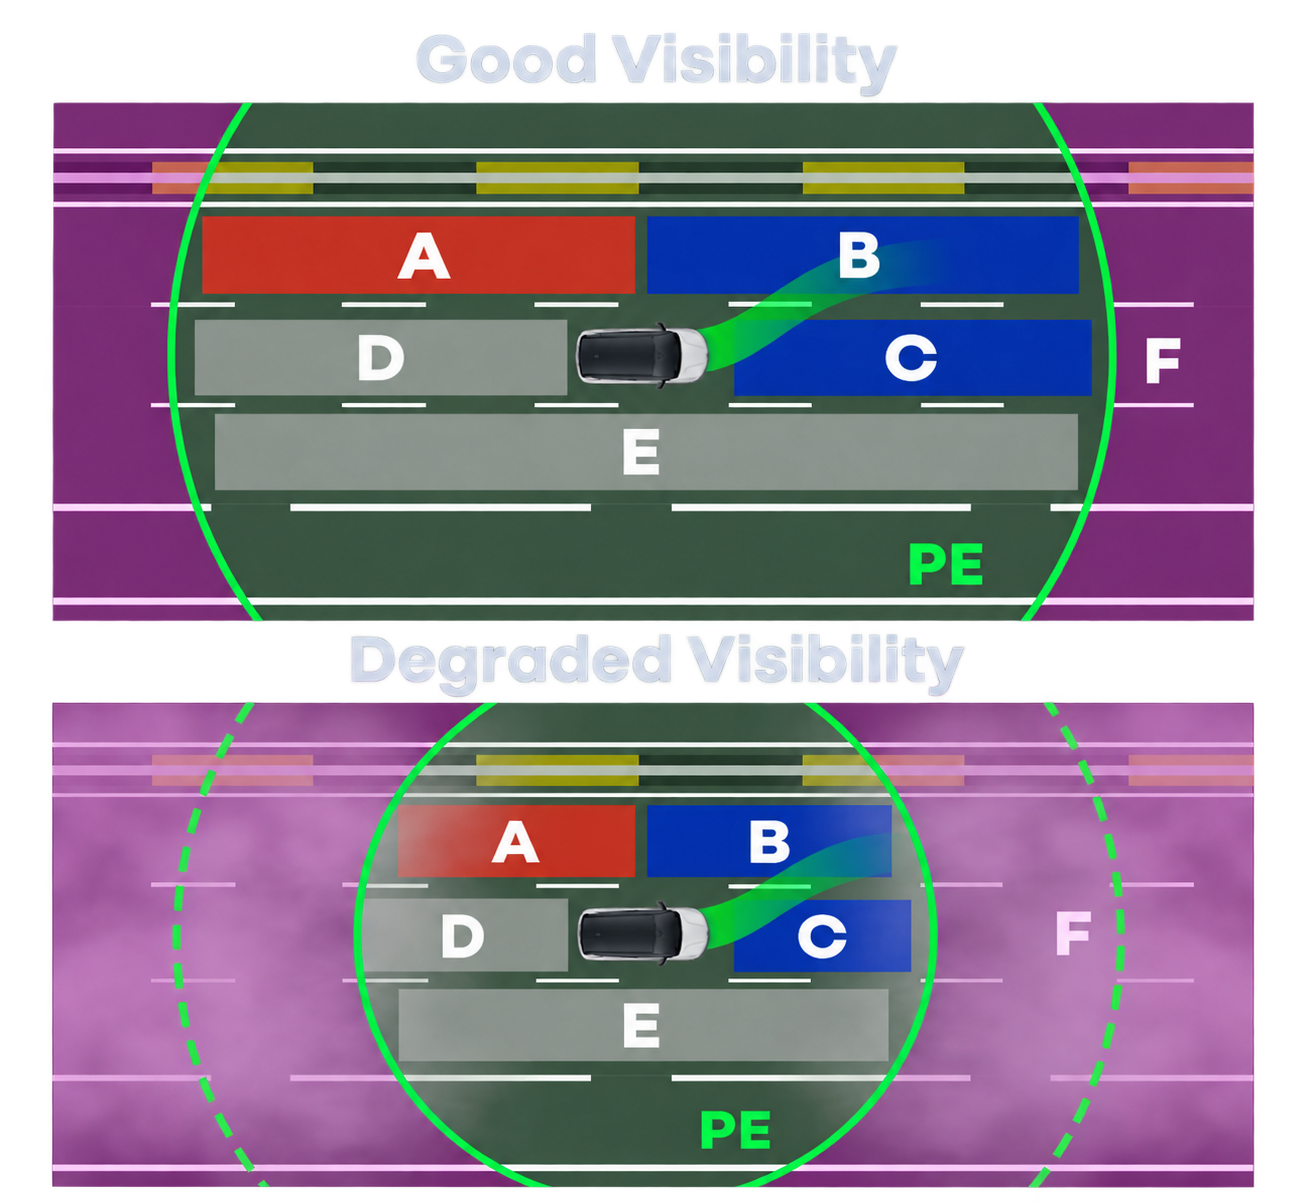
  • Designed a behavior planning framework that dynamically maps vehicle capabilities to enable fail-operational behavior and graceful degradation under ODD transitions.
  • Modeled sequential decisions with MDPs and POMDPs, using Value Iteration and Monte Carlo planning (POMCP) to reason under uncertainty.
  • Built a modular planning system in C++ and Python on ROS 2 for real-time integration into an industrial software architecture.
  • Validated through SIL, VIL, and prototype-vehicle experiments on controlled tracks.
  • Benchmarked against baseline planning models to assess tactical safety and operational continuity under capability limitations and ODD changes.

R&AE Intern – HMI Decision System

Renault Group, Aubevoye

Feb 2022 – Aug 2022
  • Developed a ROS-based interactive system for selecting tactical maneuvers in highway driving scenarios.
  • Designed maneuver feasibility and safety validation logic.
  • Studied user interaction with maneuver-based autonomous driving in simulation.

R&D Intern – Assistant Engineer

NW Technology

Sep 2020 – Feb 2021
  • Designed a flexible polymer shell for aerodynamic pressure sensors using 3D printing.
  • Developed a Python HMI for GCODE post-processing.

R&D Intern – Graduate Technical Internship

I21 Innovation, Cagnes-sur-Mer

Apr 2019 – Jun 2019
  • Developed energy management and energy harvesting solutions for low-power connected embedded systems.
  • Programmed ATmega328P and STM32 microcontrollers in C++ for sensing, transmission, and system optimization.

Academic experience

Teaching and hands-on support for engineering students.

Teaching Assistant – Python Programming

Université de Technologie de Compiègne

Sep 2026 – Present
  • Supervise and assess Python programming laboratories for engineering students, covering core programming concepts, object-oriented programming, scientific computing, and databases.

Teaching Assistant – Control Systems

Université de Technologie de Compiègne

Oct 2023 – Feb 2024
  • Supervised master-level laboratories in system modeling and feedback control.
  • Guided hands-on experiments using MATLAB/Simulink for system analysis and implementation.

Fablab Monitor

UTC Innovation Center

Oct 2019 – Jan 2020
  • Supported engineering students in CAD modeling and rapid prototyping.
  • Assisted with 3D printers, laser cutting, and digital manufacturing equipment.

Technical toolkit

Core competencies

AI & Decision-Making

MDP / POMDP · POMCP / Monte Carlo Tree Search · Dynamic Programming · Deep RL: DQN, Policy Gradients, Actor-Critic · Machine Learning & Deep Learning

Robotics & Validation

ROS 2 · IPG CarMaker · CARLA · Gazebo · MATLAB/Simulink · SIL / VIL · Prototype-vehicle testing

Programming & Frameworks

Python · C++ · PyTorch · Keras · scikit-learn · Git · Linux · Visual Studio

Engineering & Embedded Systems

Catia V5 · SolidWorks · STM32 · Arduino · LabVIEW

Projects & Leadership

Explore selected projects, my contributions, and the work behind them.

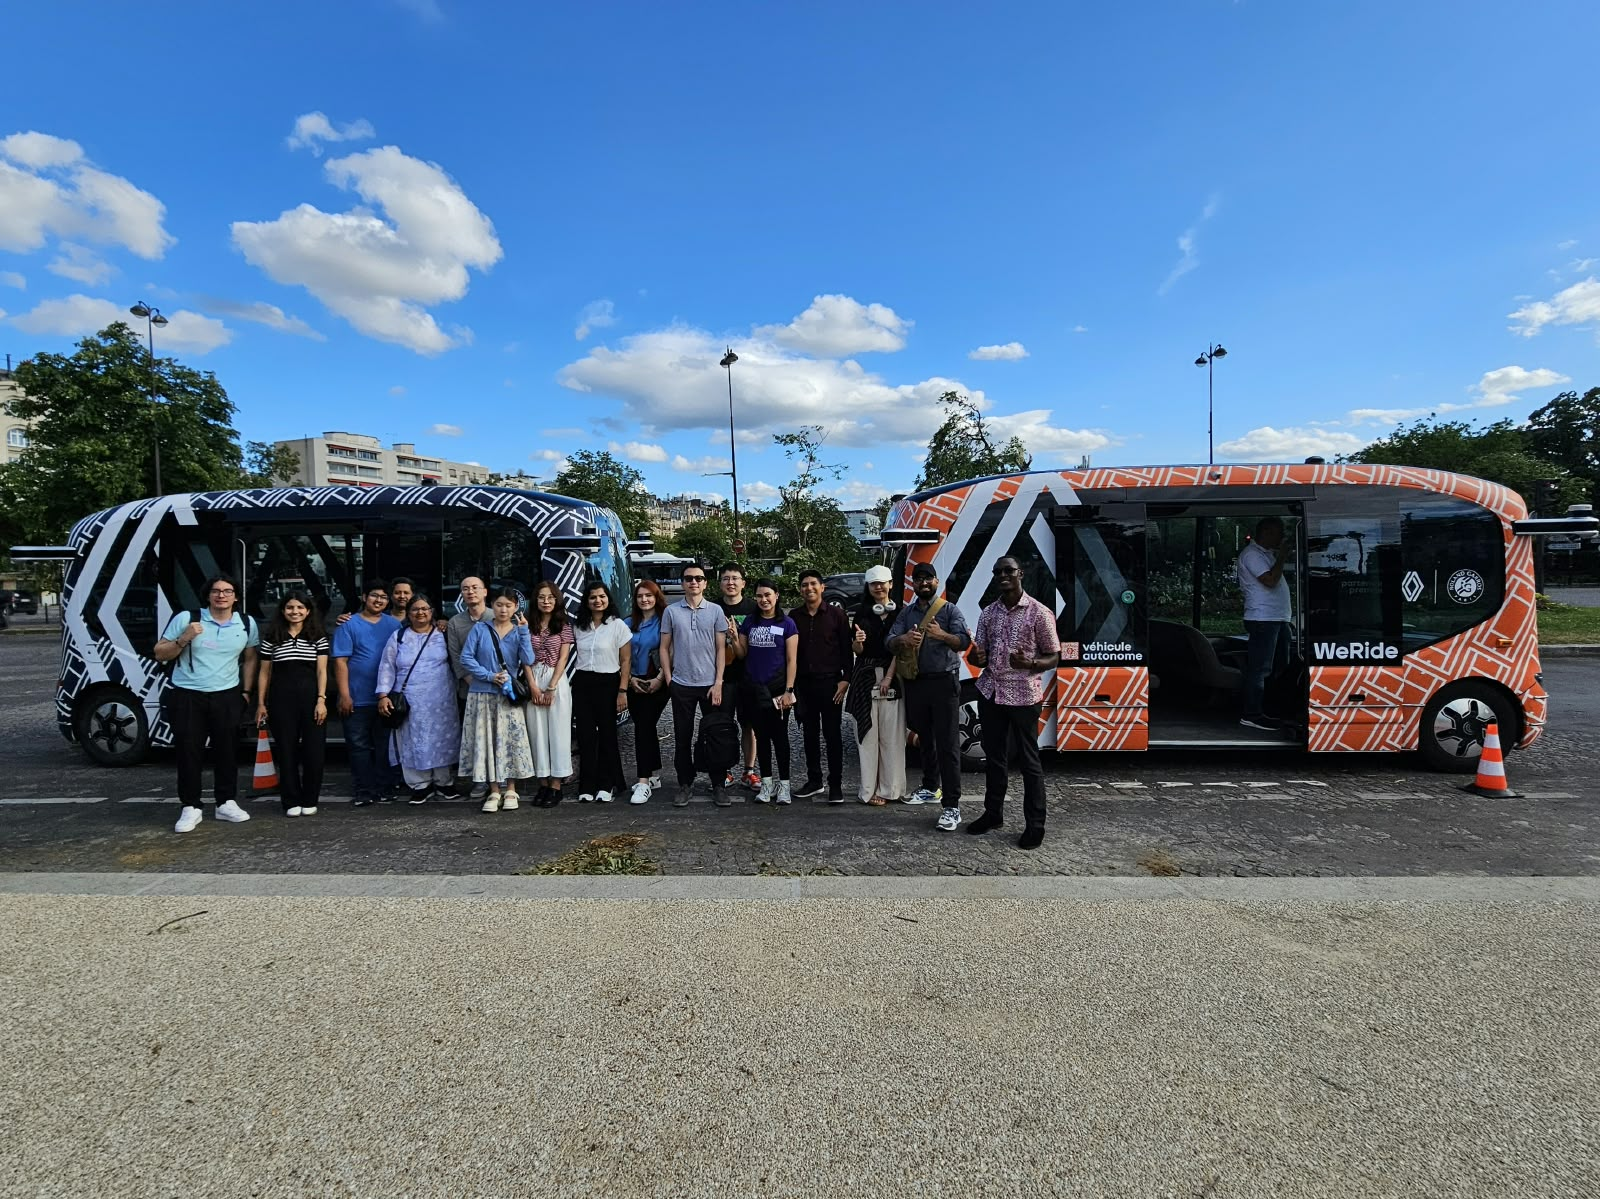
VAMS participants gathered beside two autonomous shuttles during demonstrations in Paris.
IEEE VAMS 2025 · Autonomous shuttle demonstrations, Paris

IEEE VAMS 2025 · Organizing Committee

CNAM, Paris · August 2025. Organizing committee member for the 2nd IEEE International Symposium on Verification of Autonomous Mobile Systems. Developed the registration website and coordinated speaker and attendee activities during autonomous shuttle demonstrations.

  • Autonomous Systems
  • Web Development
  • Event Organization
View project →
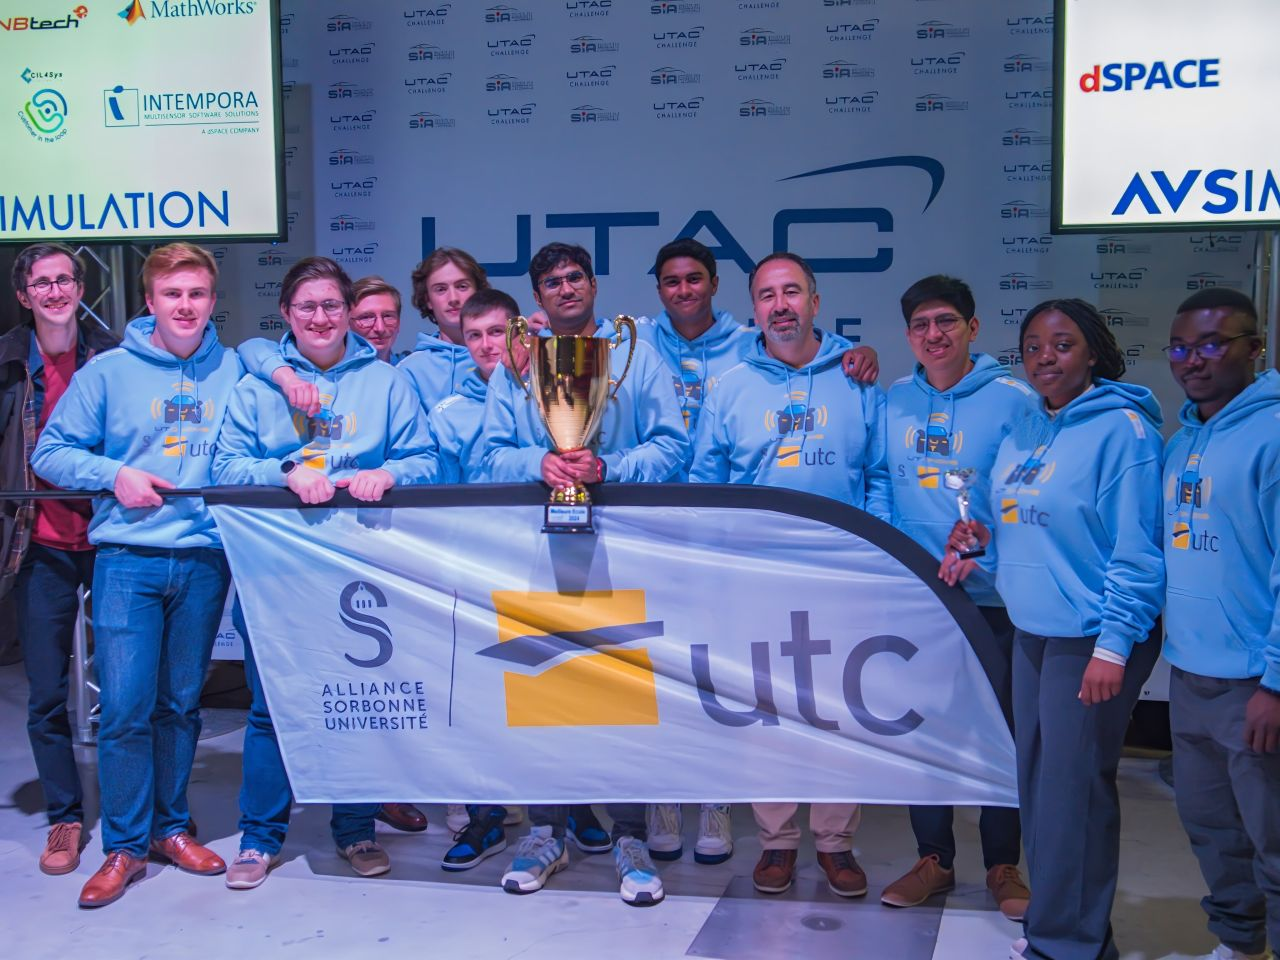
The UTC team celebrating with its trophies at the UTAC Challenge 2024.
UTC team · UTAC Challenge 2024

UTAC Challenge 2024

Mentored the UTC student team during the UTAC Challenge 2024, the first European competition in a real-world environment dedicated to autonomous and connected mobility. Supervised the development of the 'UTonome On Demand' (UTOD) system using CARLA and MATLAB for simulation. Results: 2nd place (Open Category) and Best School Award.

  • CARLA
  • MATLAB
  • Autonomous Driving
  • Mentoring
View project →
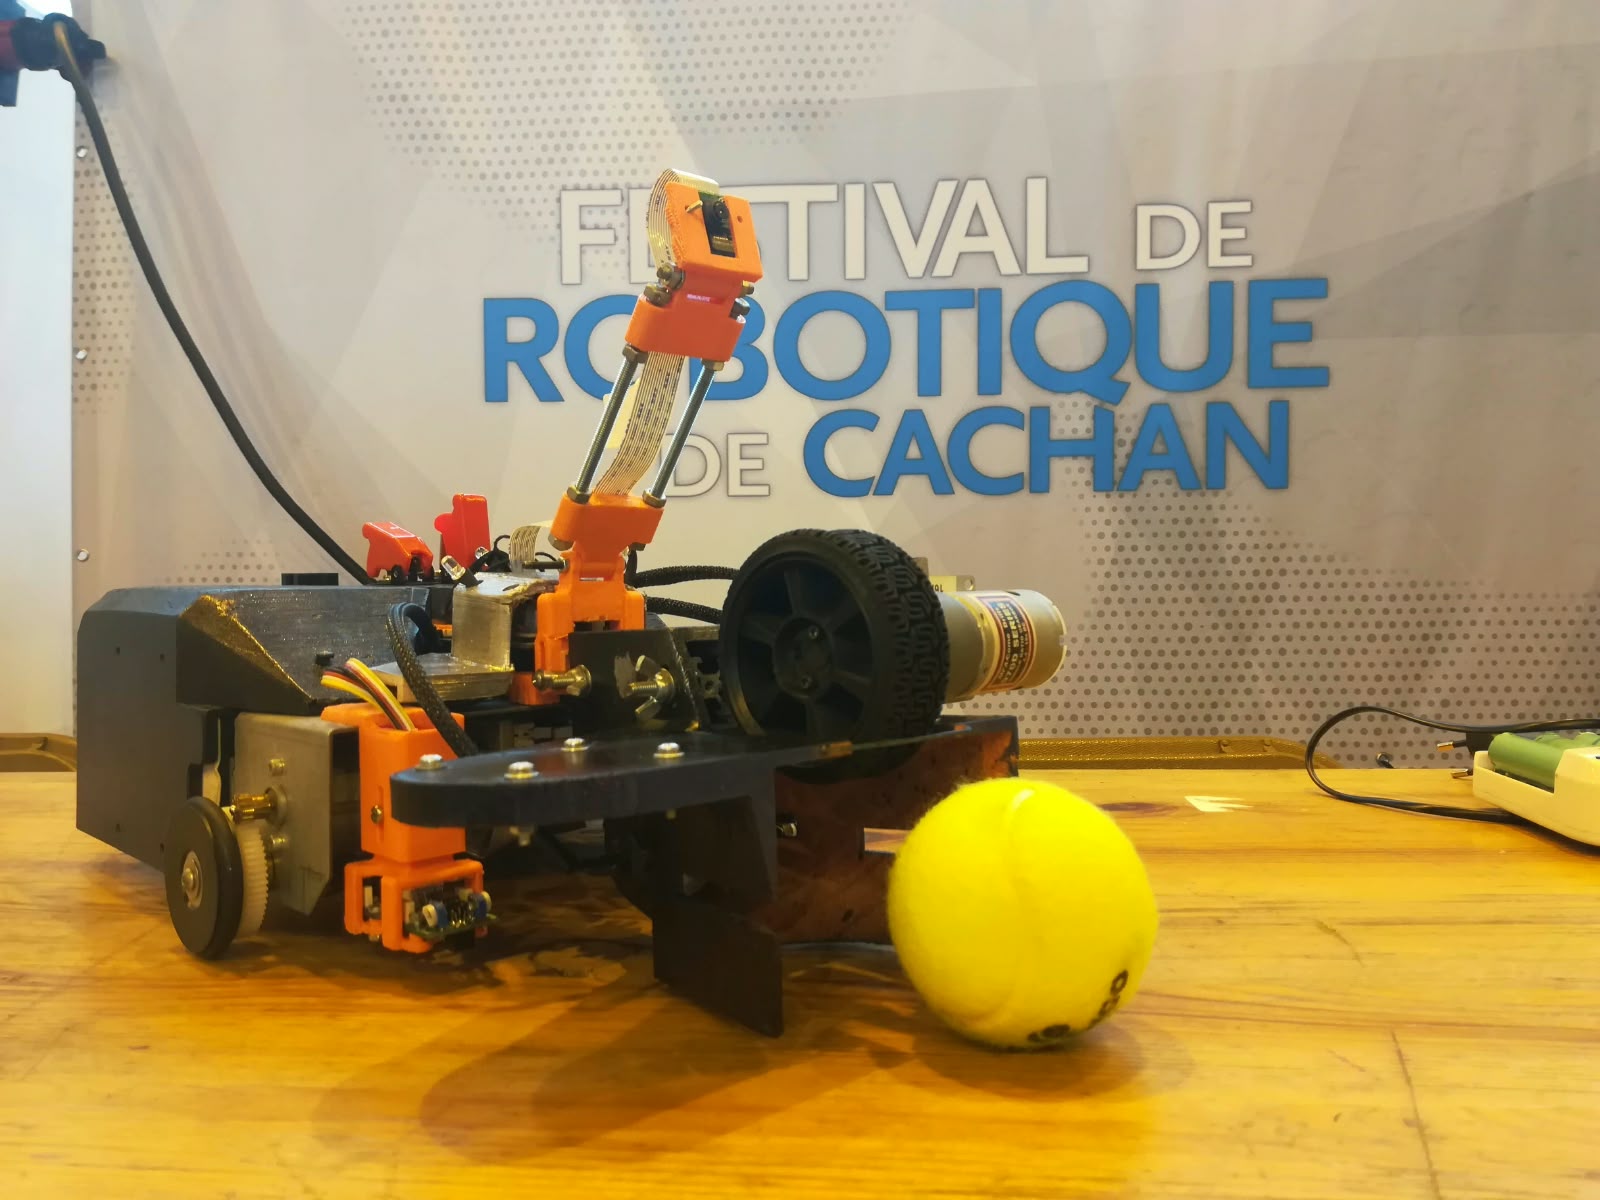
The autonomous tennis robot with its mechanical arm and a tennis ball at the Festival de Robotique de Cachan.
Autonomous tennis robot · IUT competition, Cachan

National IUT Robotics Competition · Cachan

Designed and developed an autonomous robotic platform capable of simulating a tennis match at IUT Nice Côte d’Azur (Oct 2018–Apr 2019). Contributed to mechanical design, embedded electronics, and software development.

  • SolidWorks
  • 3D Printing
  • Electronics
  • Robotics
View project →
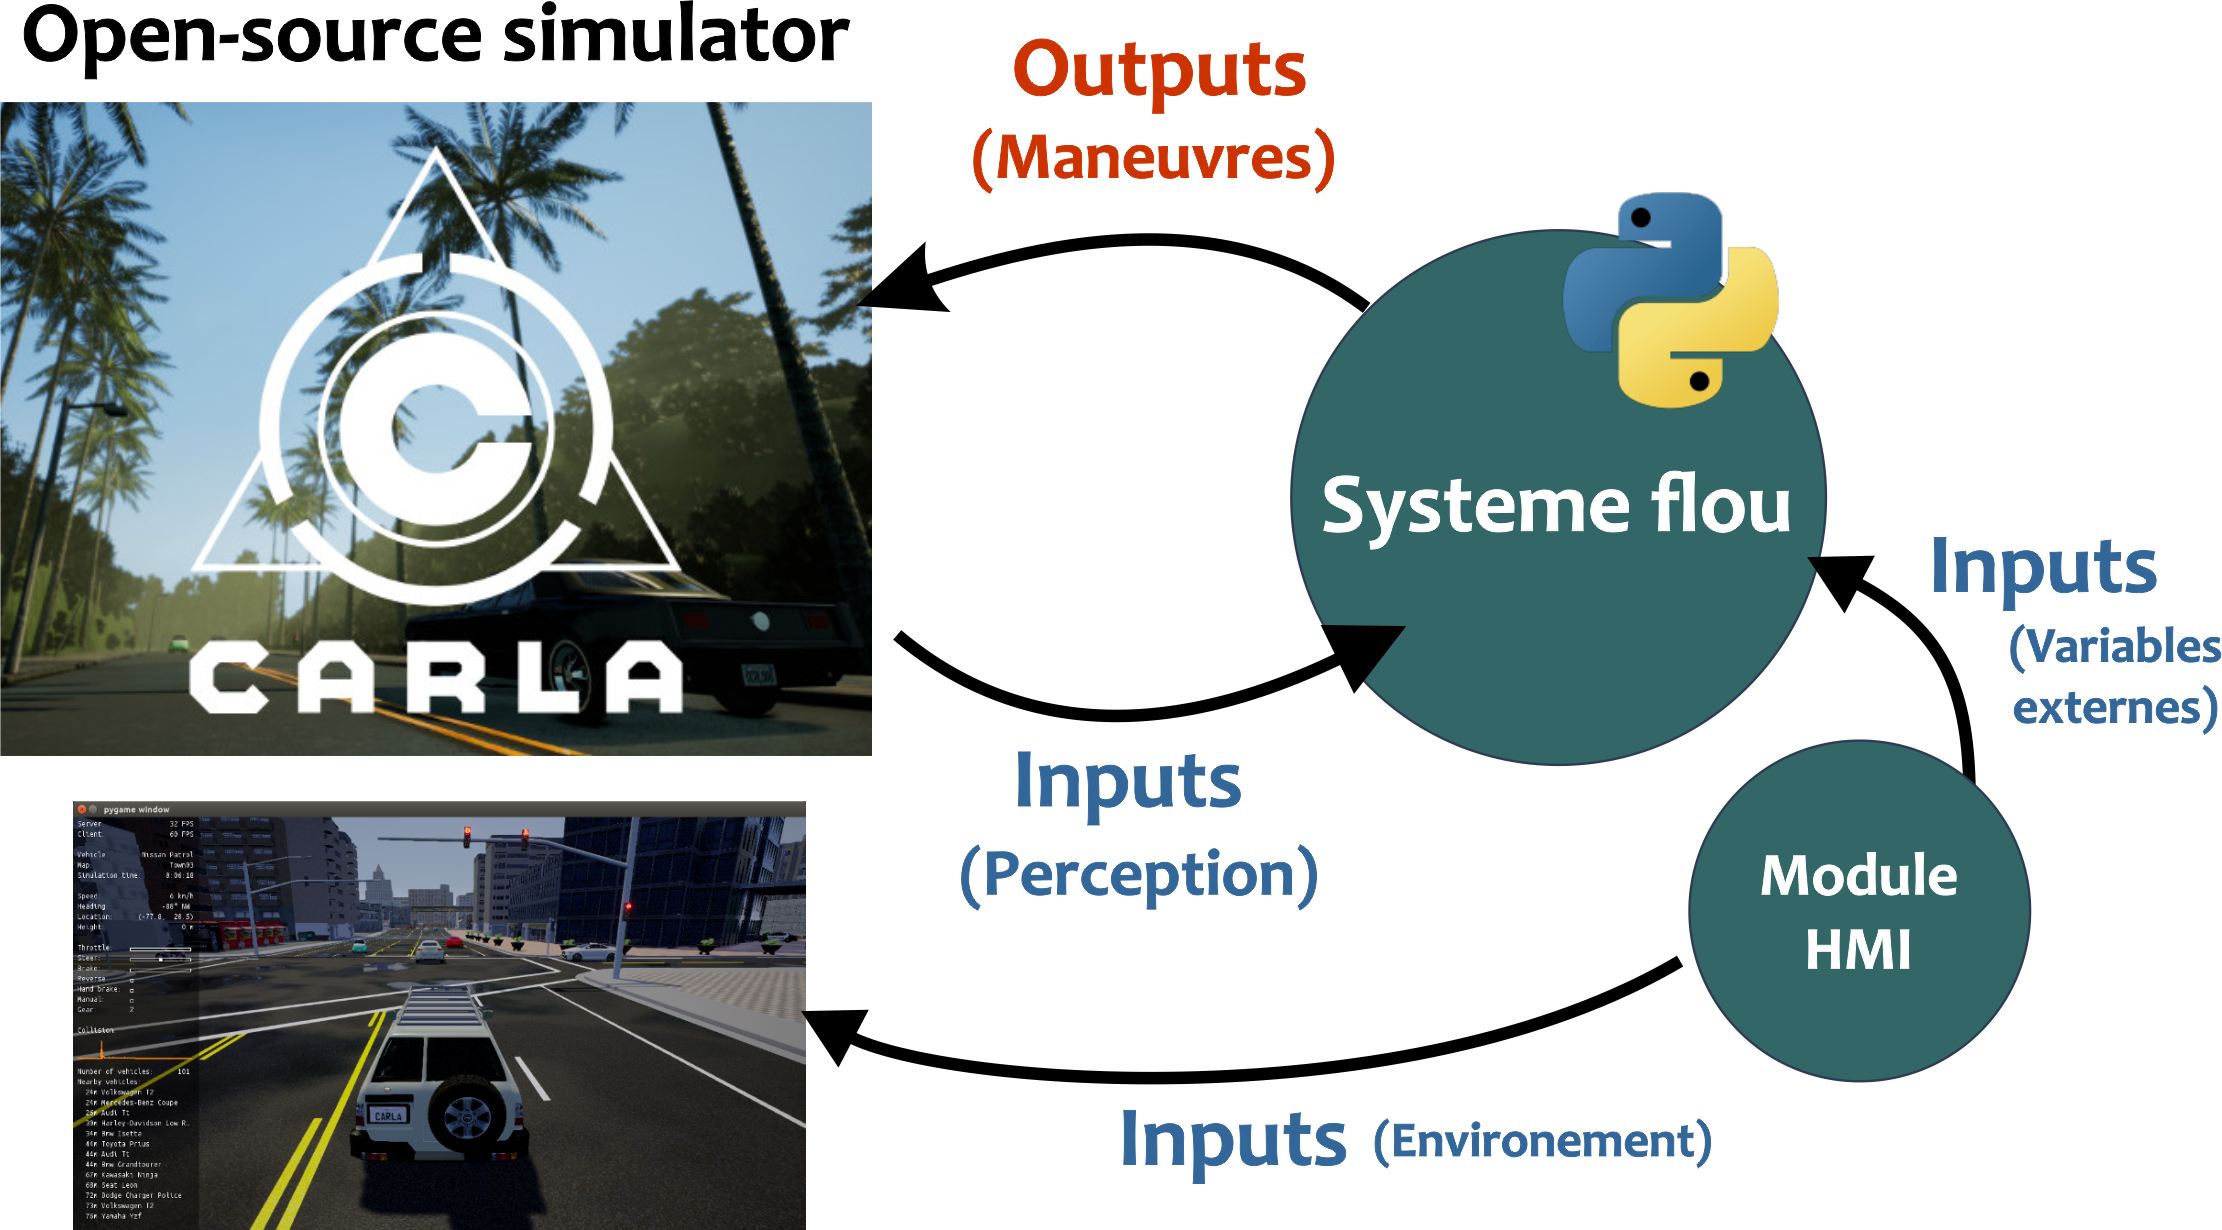
Overview of the CARLA fuzzy decision-making system, with perception, environment inputs, maneuver outputs, and an HMI module.
Fuzzy decision-making framework · CARLA & Python

Fuzzy System for CARLA

Tactical driving of vehicles using a fuzzy logic system for decision-making in the CARLA autonomous driving simulator. Open-source implementation.

  • Python
  • Fuzzy Logic
  • CARLA
  • Decision-Making
View project →

Quadruped Robot for Underground Mine Exploration

Technical Supervisor · National University of Engineering, Peru · Feb–Dec 2025. Developed and supervised ROS 2 and Gazebo simulation workflows for autonomous underground mine exploration. Mentored student teams on integration, route planning, and decision-making.

  • ROS 2
  • Gazebo
  • Route Planning
  • Technical Supervision
View project →

Publications

Engagement & Outreach

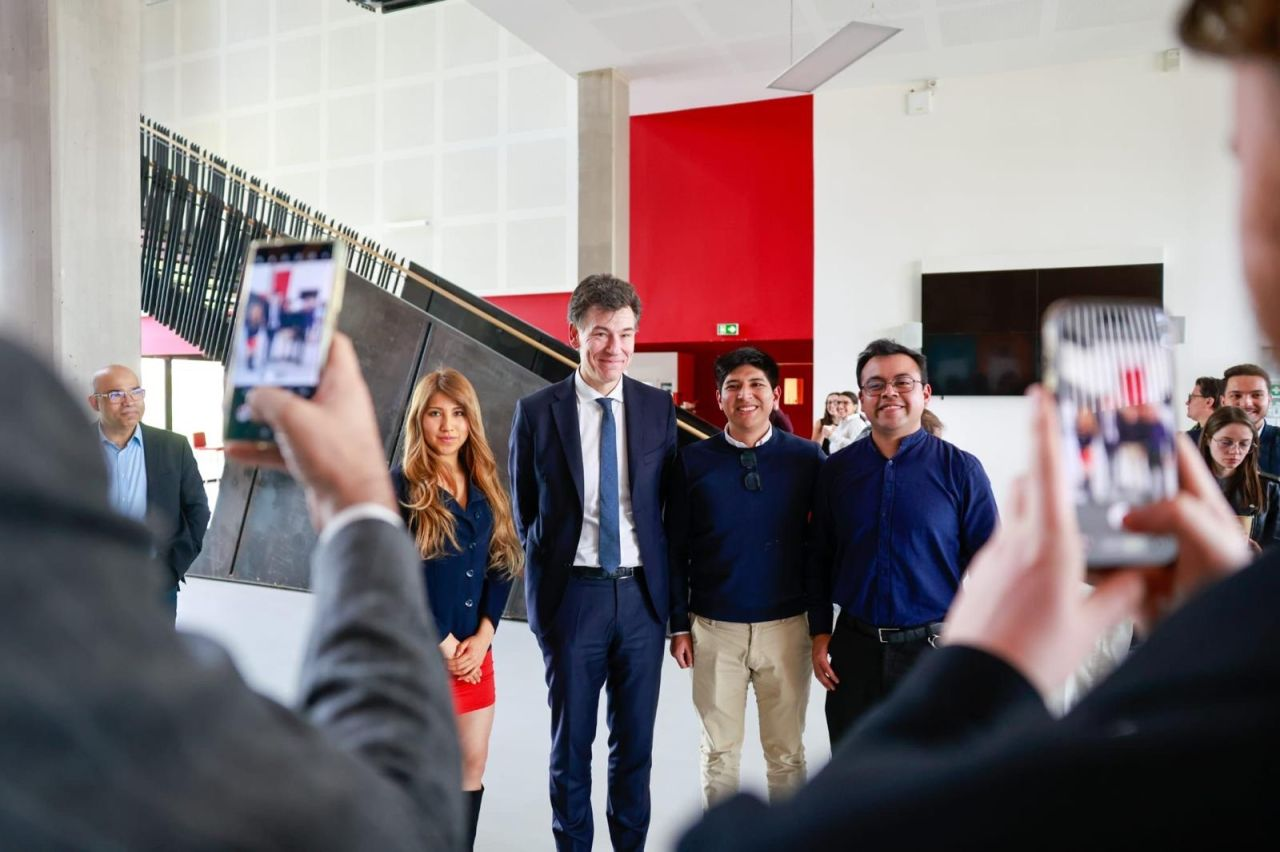
A group photograph at UTC during Philippe Baptiste’s visit, following the roundtable on international talent and research.

Roundtable at UTC

21 April 2026 · UTC, Compiègne

Participation in a discussion on international talent and research in France with fellow doctoral researchers, during Philippe Baptiste’s visit to UTC.

Education

PhD in Control and Robotics (CIFRE)

Université de Technologie de Compiègne × Renault

2023 – 2026
  • Industrial research partnership with Renault Group
  • Focus: Decision-making for intelligent vehicles
  • PhD defense scheduled for December 2026
  • Published in IEEE Transactions on Intelligent Vehicles

MEng Mechanical Engineering, Mechatronics

Université de Technologie de Compiègne

2019 – 2023
  • Specialization in robotics and control systems
  • Final project at Renault on autonomous vehicles

DUT Electrical Engineering & Industrial Computing

IUT Nice Côte d'Azur

2017 – 2019
  • Foundation in electronics and embedded systems
  • Internship at I21 Innovation

Studies in Mechatronics Engineering

National University of Engineering, Peru

2015 – 2017
  • Engineering studies prior to continuing my education in France.

AI Courses & Certifications

Udacity · 2026

Deep Reinforcement Learning Nanodegree

DQN, policy gradients, actor-critic algorithms, continuous control, and multi-agent reinforcement learning.

Udacity · 2026

Self-Driving Car Engineer Nanodegree

Deep learning, computer vision, object detection, sensor fusion, localization, motion planning, and vehicle control.

DeepLearning.AI & Stanford Online · 2023

Machine Learning Specialization

Supervised and unsupervised learning, neural networks, regression, classification, decision trees, and model evaluation.

Languages

  • Spanish Native
  • French C1
  • English C1
  • Italian A2
  • German A2